Roboracer

A 1/10-scale autonomous racing team turning an F1-inspired platform into a fast, reliable testbed for perception, localization, and planning.

Roboracer LeadAndrew Chen

Autonomy at one-tenth scale

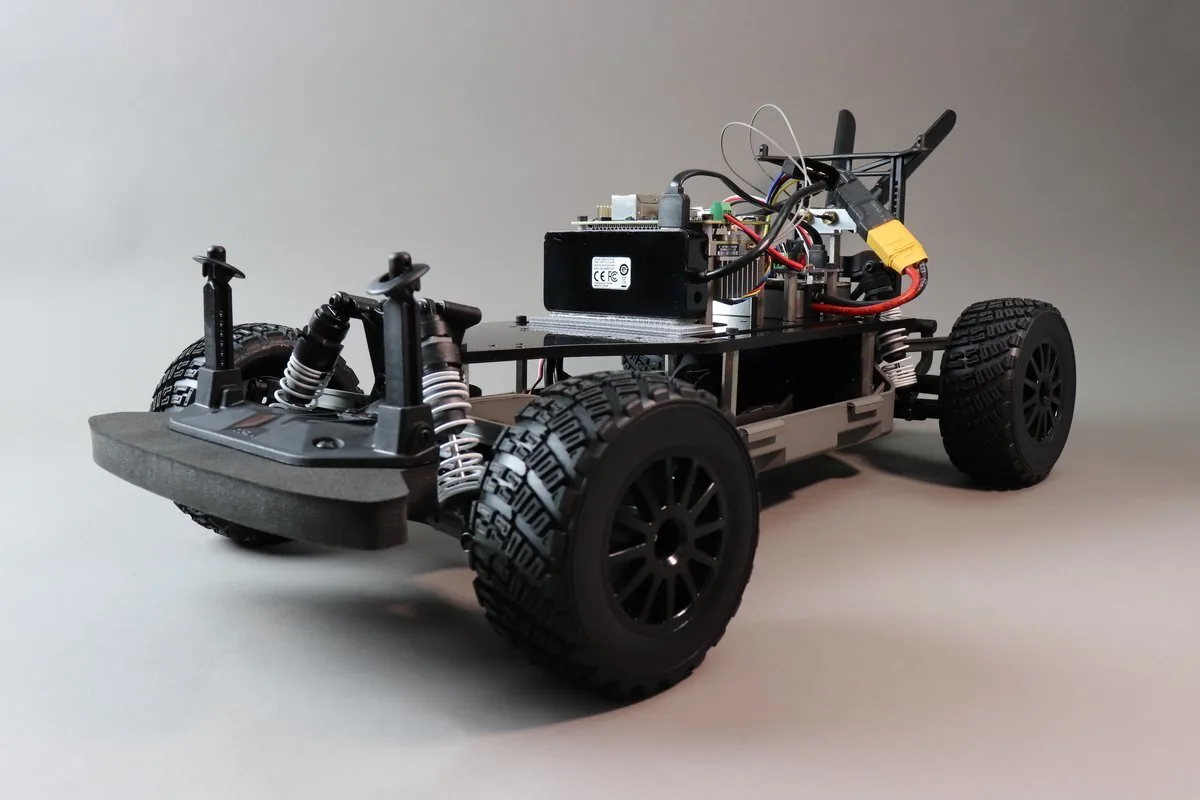
Roboracer works on an F1-inspired autonomous vehicle small enough for rapid testing while still presenting the core challenges of a full robotics stack.

Members connect sensing, computation, controls, and vehicle hardware into a platform that can understand its position and navigate a planned course.
Roboracer autonomous vehicle with onboard sensors and electronics
The 1/10-scale autonomous racing platform

Localization and path planning

The team focused this year on finalizing localization and path-planning systems. Localization now works through SLAM Toolbox and AMCL alongside waypoint-based path planning.

Together, these systems let the vehicle build or use a map, estimate where it is, and follow a repeatable route.

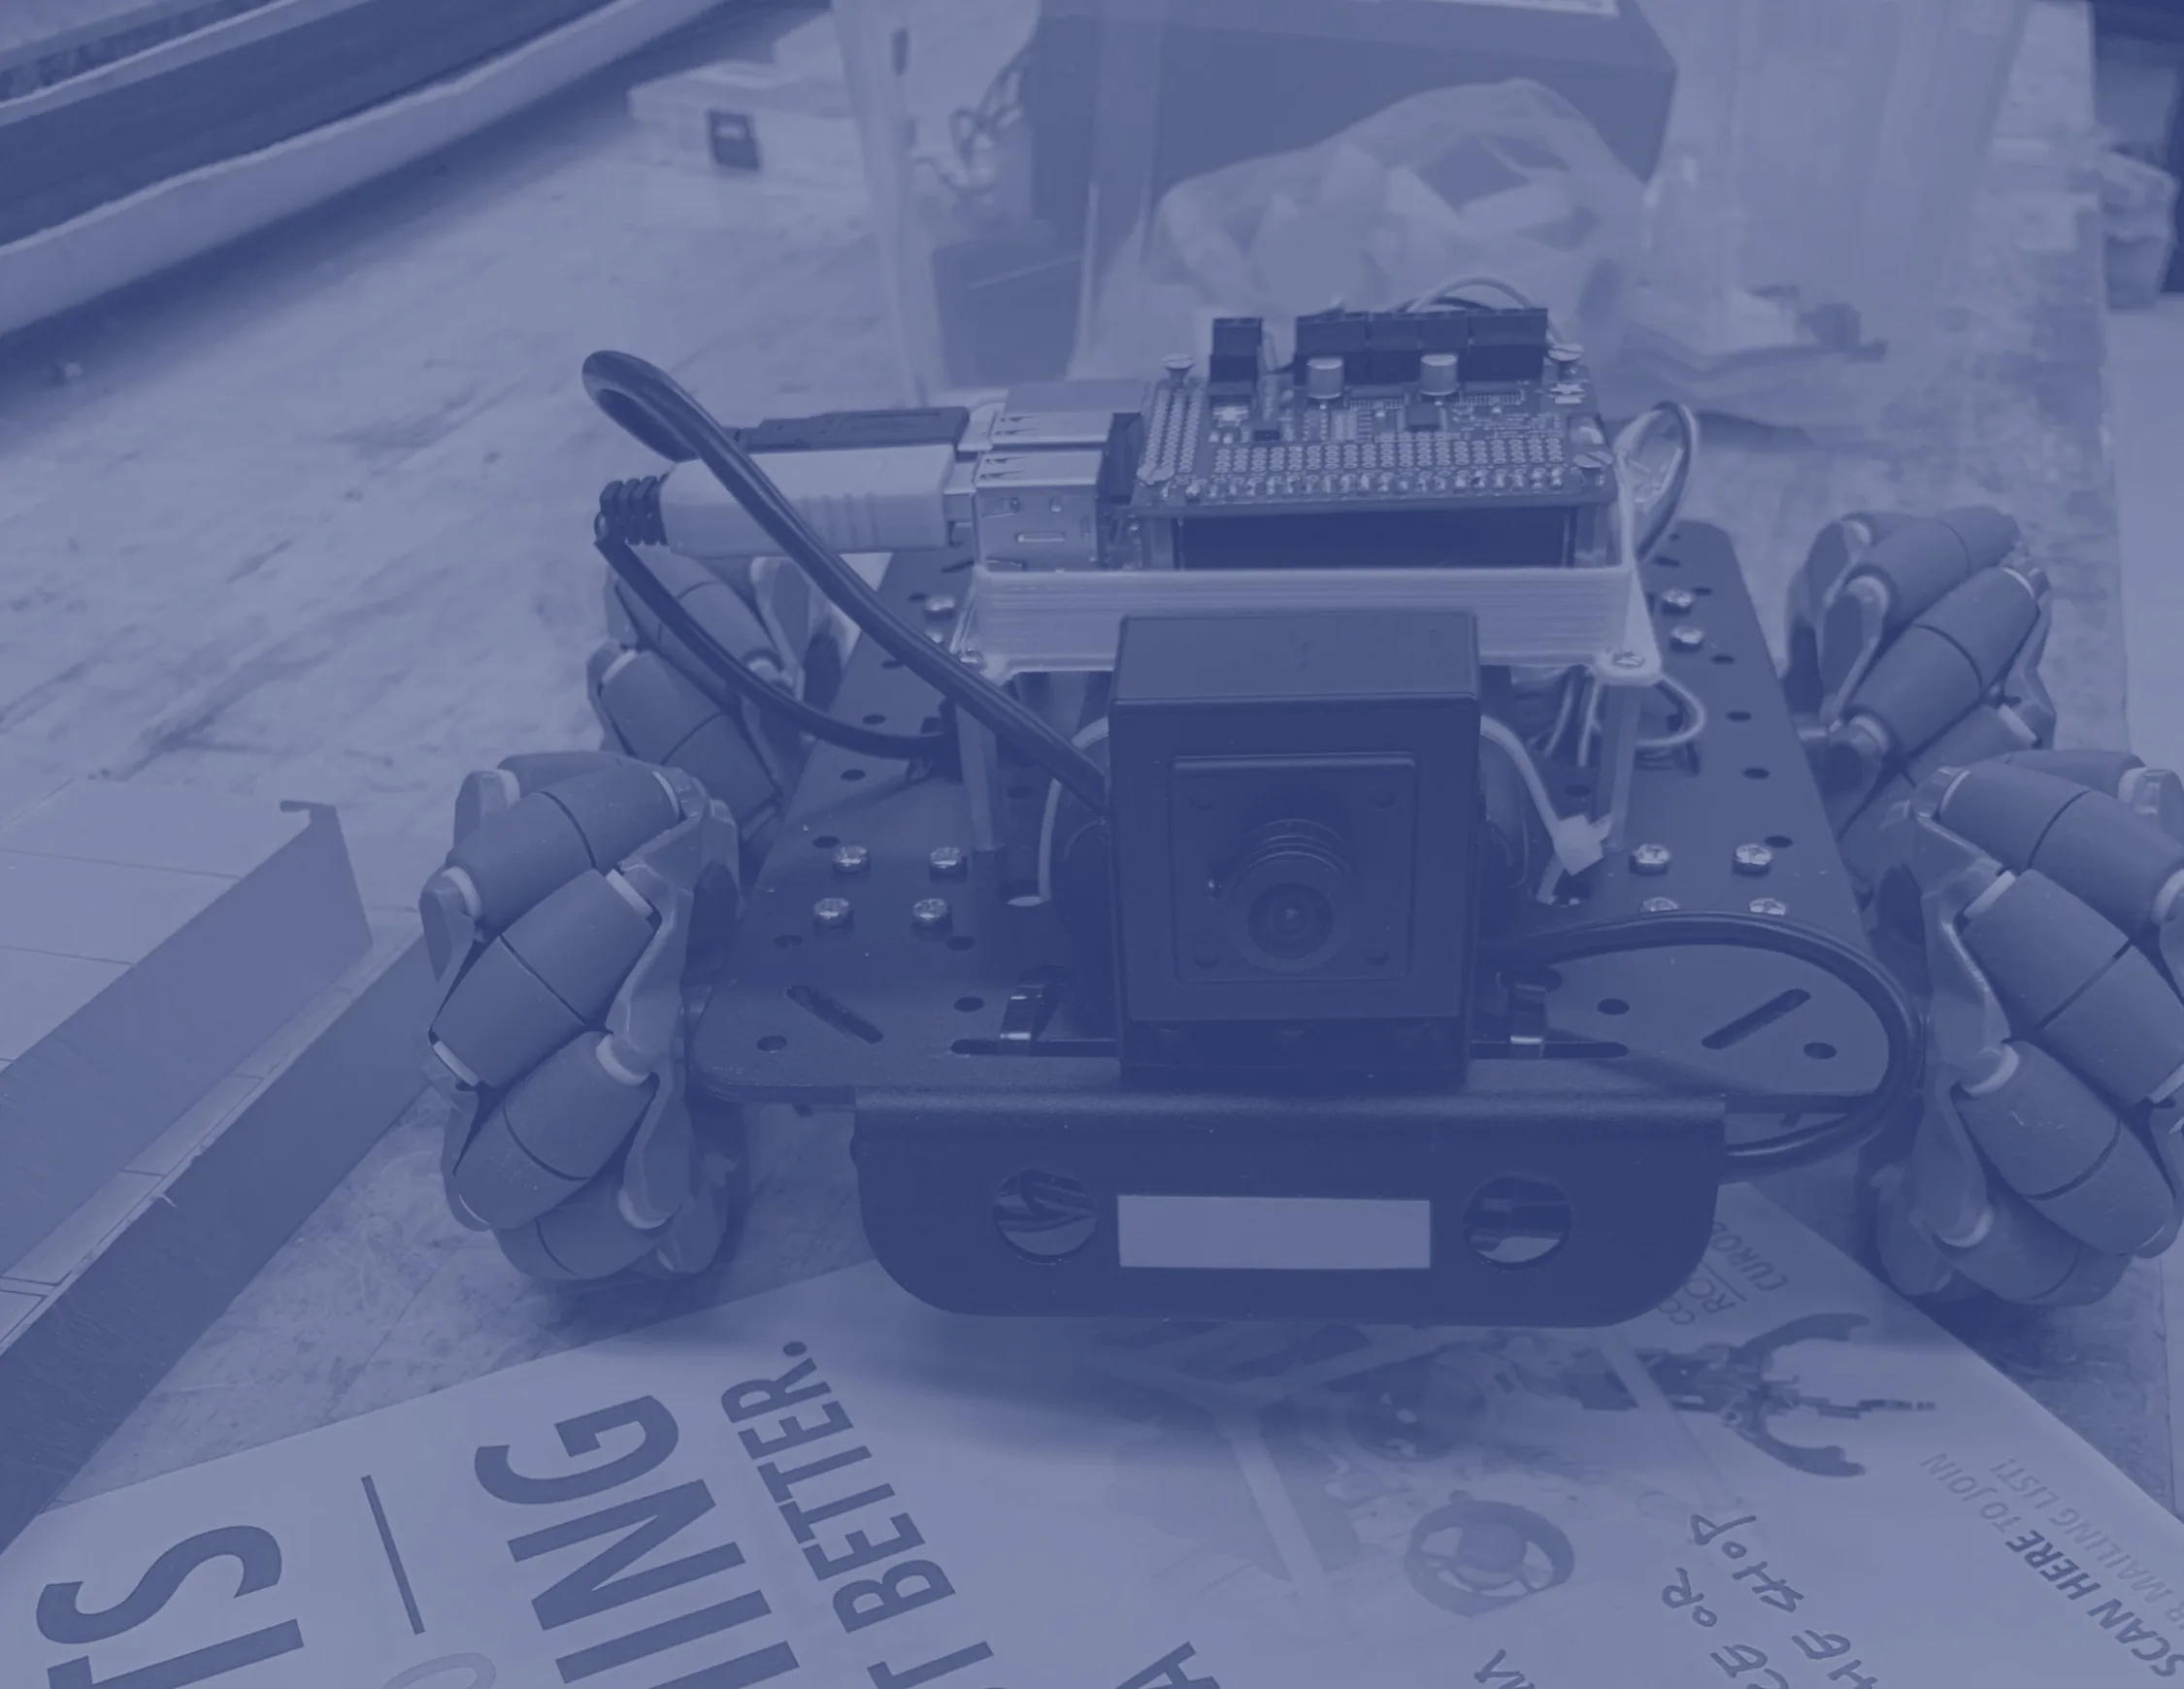
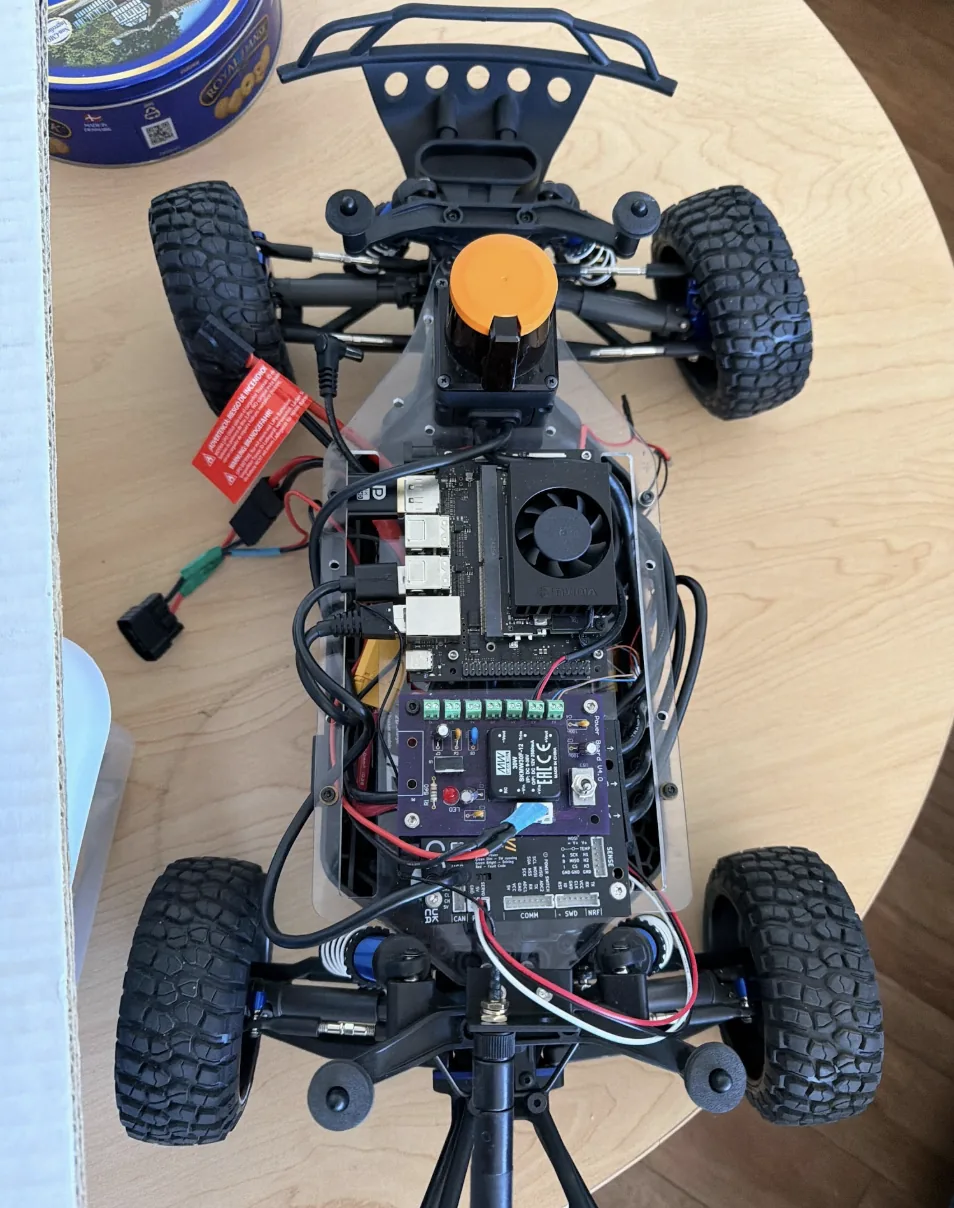
Roboracer autonomous vehicle hardware and onboard electronics
Onboard computing and electronics for autonomous navigation

Quicker testing loops

Roboracer also built a custom web interface for lighter-weight testing, making it easier to exercise the autonomy stack without bringing up every part of the full system.

That faster feedback loop helps the team isolate problems, compare approaches, and spend more time improving the car's behavior.

Roboracer vehicle closer view
Just a cool close-up of the Roboracer

Members can contribute across autonomy software, controls, testing tools, and vehicle integration.