CCBR (ESRA)

An inter-university collaboration building a quadruped, then a biped, on the path toward an open-source humanoid robot.

CCBR Co-LeadLissia Leite Barbosa
CCBR Co-LeadSiena Hyun-Ju Chae

A shared robotics roadmap

CCBR (ESRA) brings together students from Columbia, Caltech, Berkeley, and Rutgers. The current quadruped is the first milestone, followed by a biped and ultimately a humanoid platform.

Members collaborate across schools while gaining hands-on experience in mechanical design, CAD, fabrication, controls, and system integration.
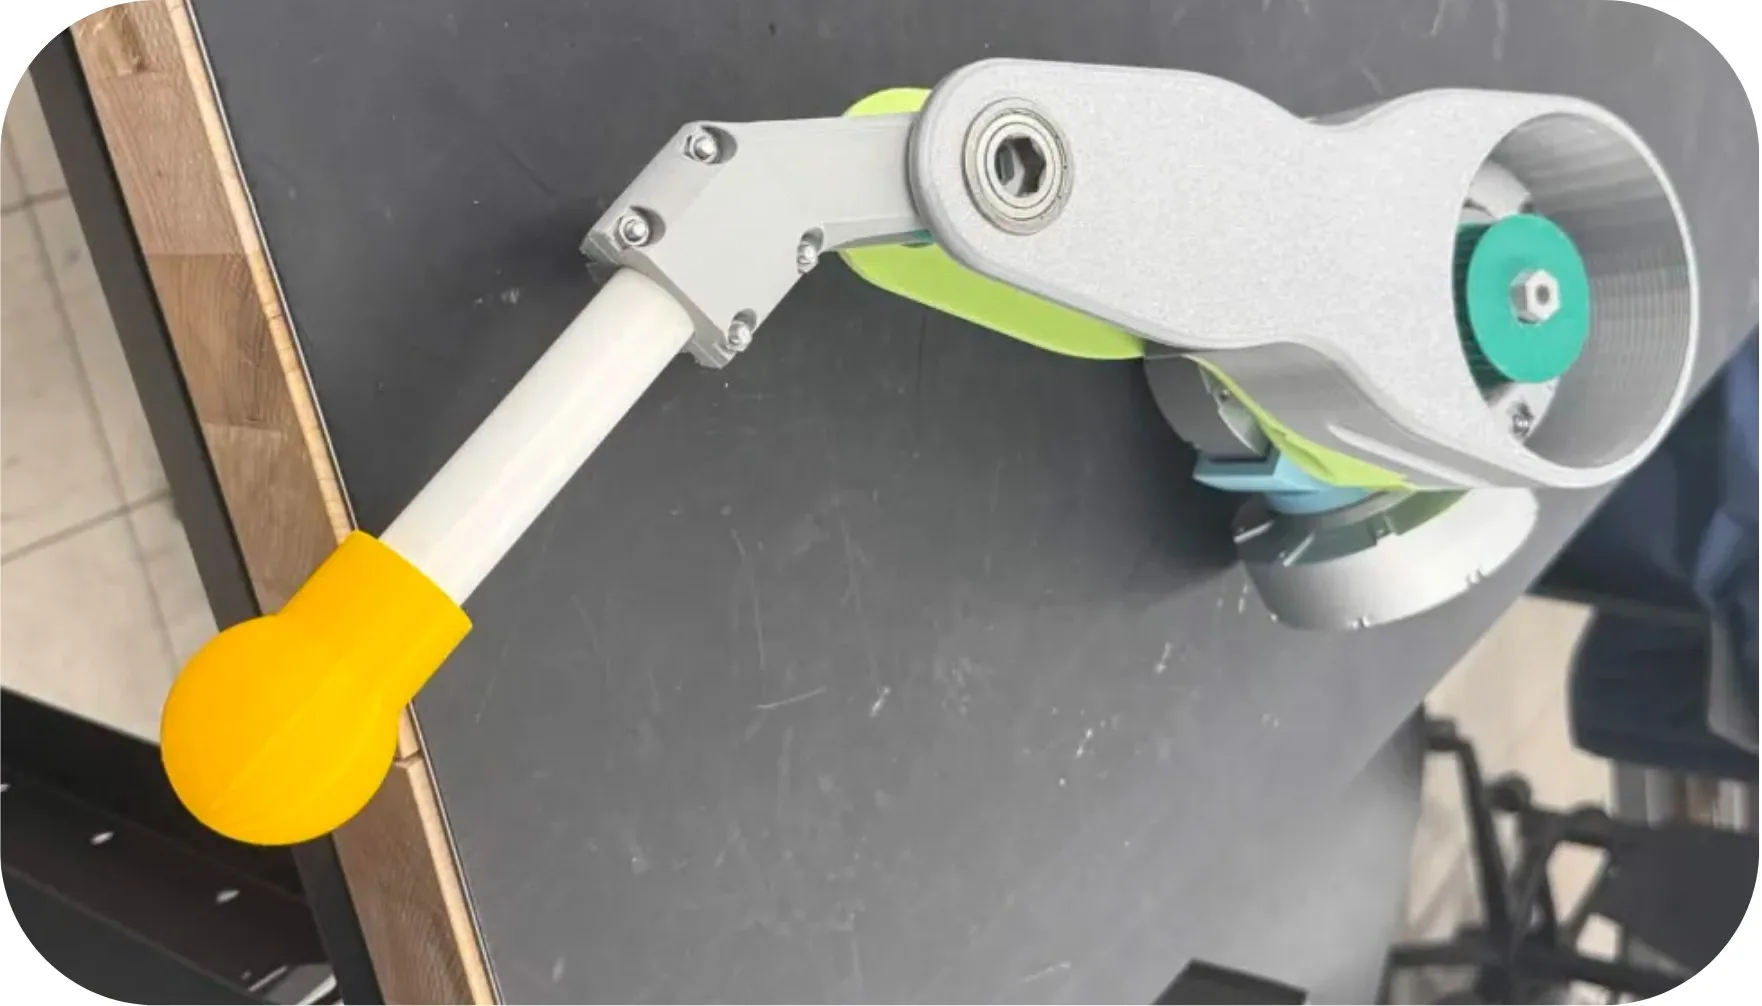
CCBR modular robot leg assembly
A modular leg assembly for the quadruped platform

The definition of robotics in a project

The project spans the complete robot stack, giving members room to specialize while still seeing how every subsystem comes together.

Mechanical

Design and build the structure with 3D printing, CNC milling, SolidWorks, and Fusion 360.

Software

Develop simulations and reinforcement-learning-based control systems.

Electrical

Design PCBs and map the robot's electronics and wiring.

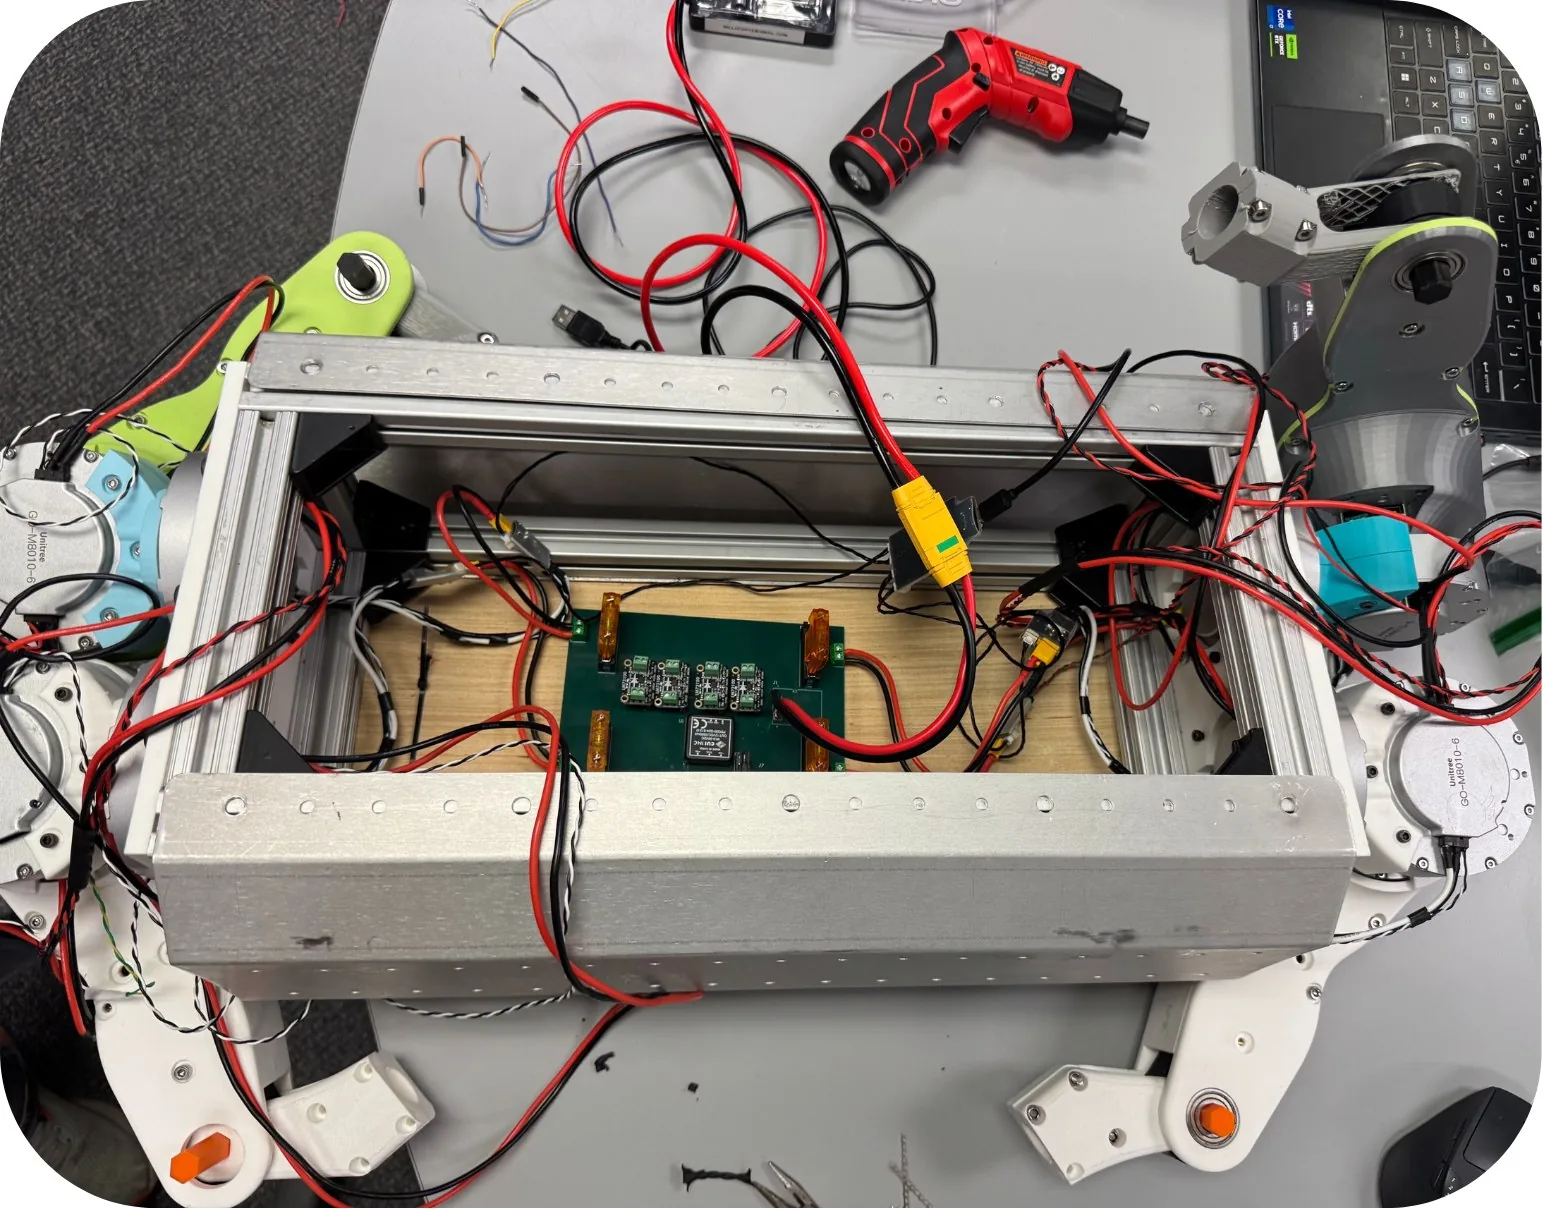
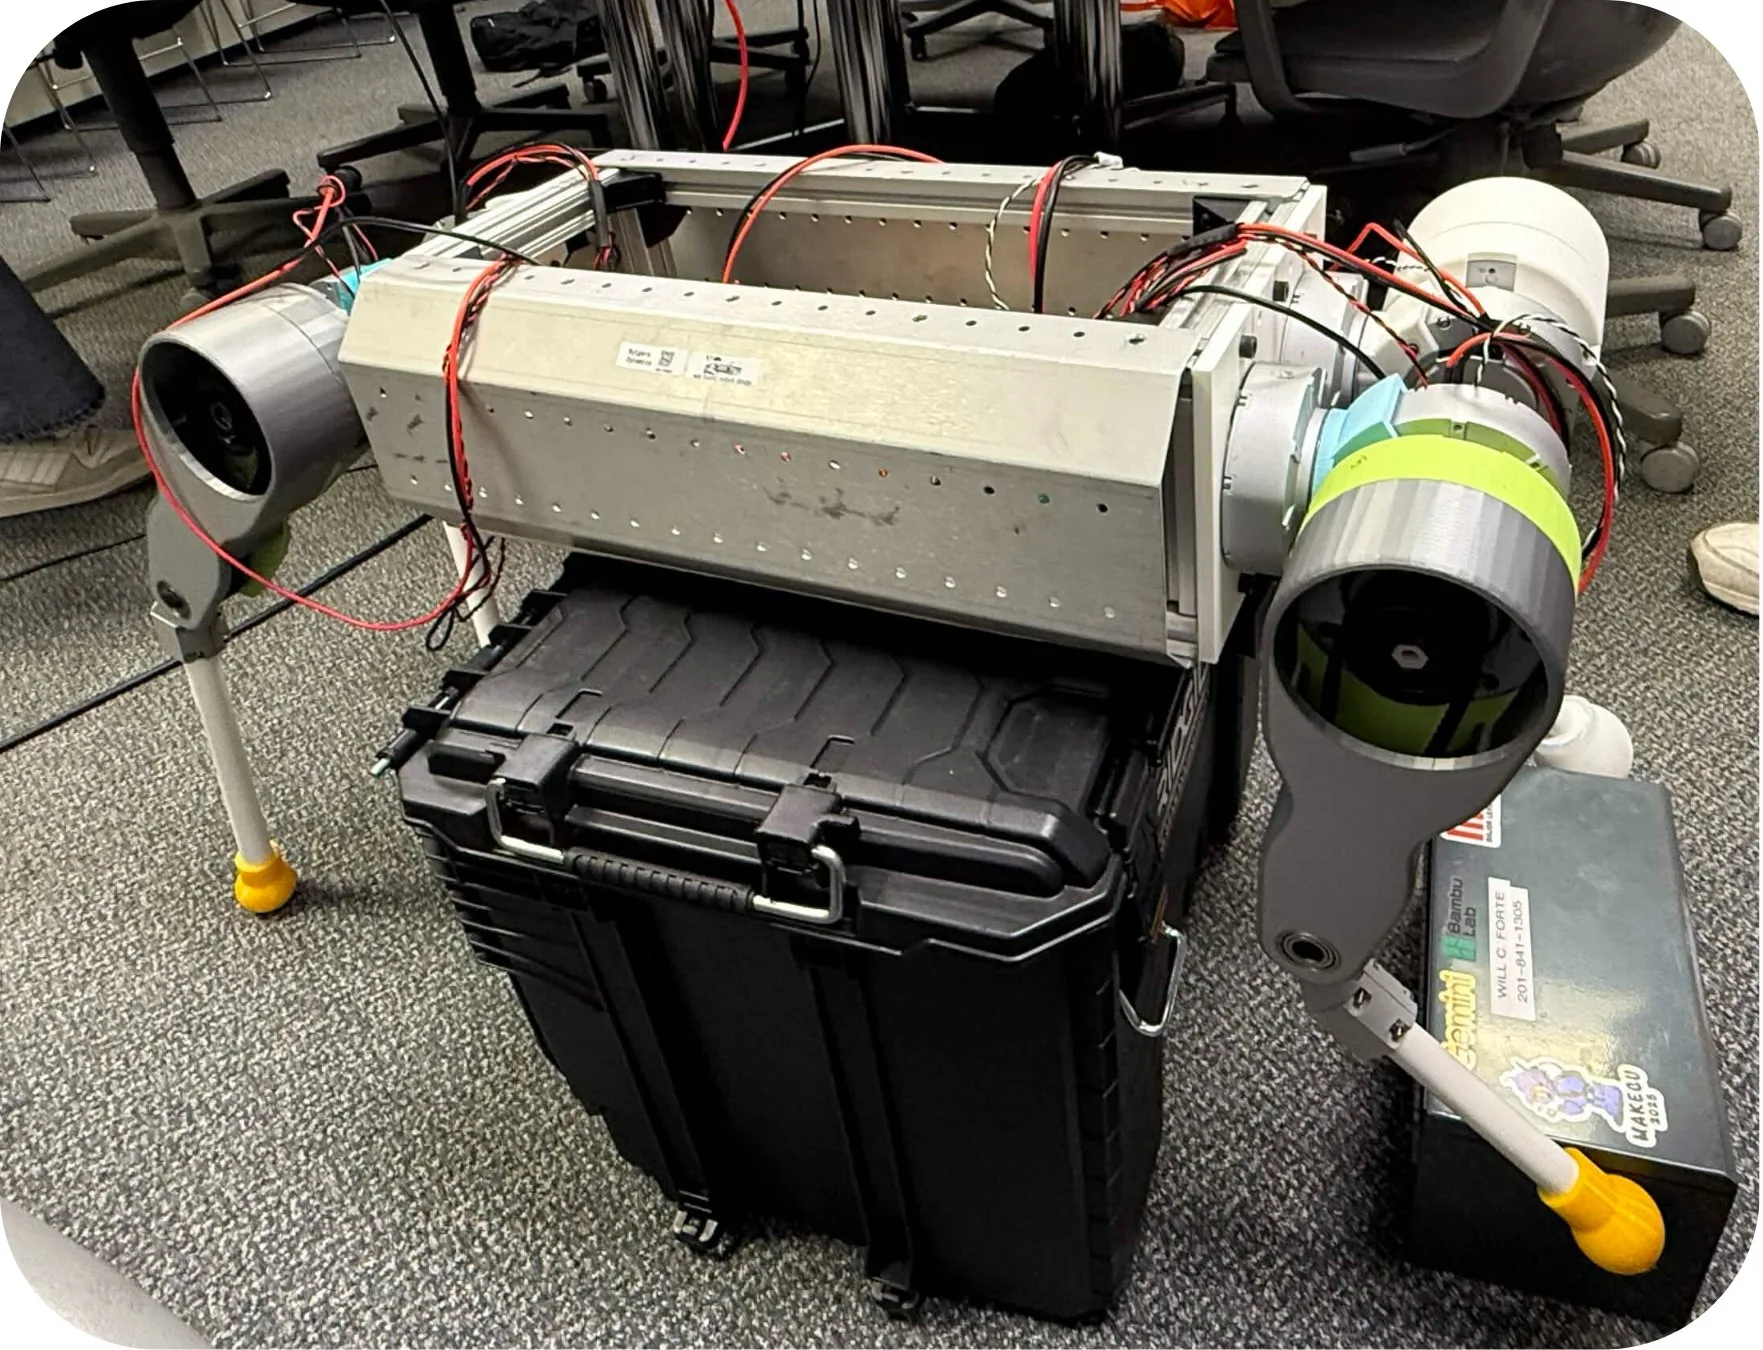
CCBR quadruped robot assembled around a transport case
The quadruped chassis during integration
Open CCBR quadruped chassis showing motors, wiring, and control electronics
Mechanical and electrical systems coming together

A platform built together

Each iteration turns ambitious legged-robotics research into accessible, documented hardware that future student teams can continue to improve.

The team is open to anyone! No prior experience is necessary. As always, bring curiosity and a willingness to participate with us.

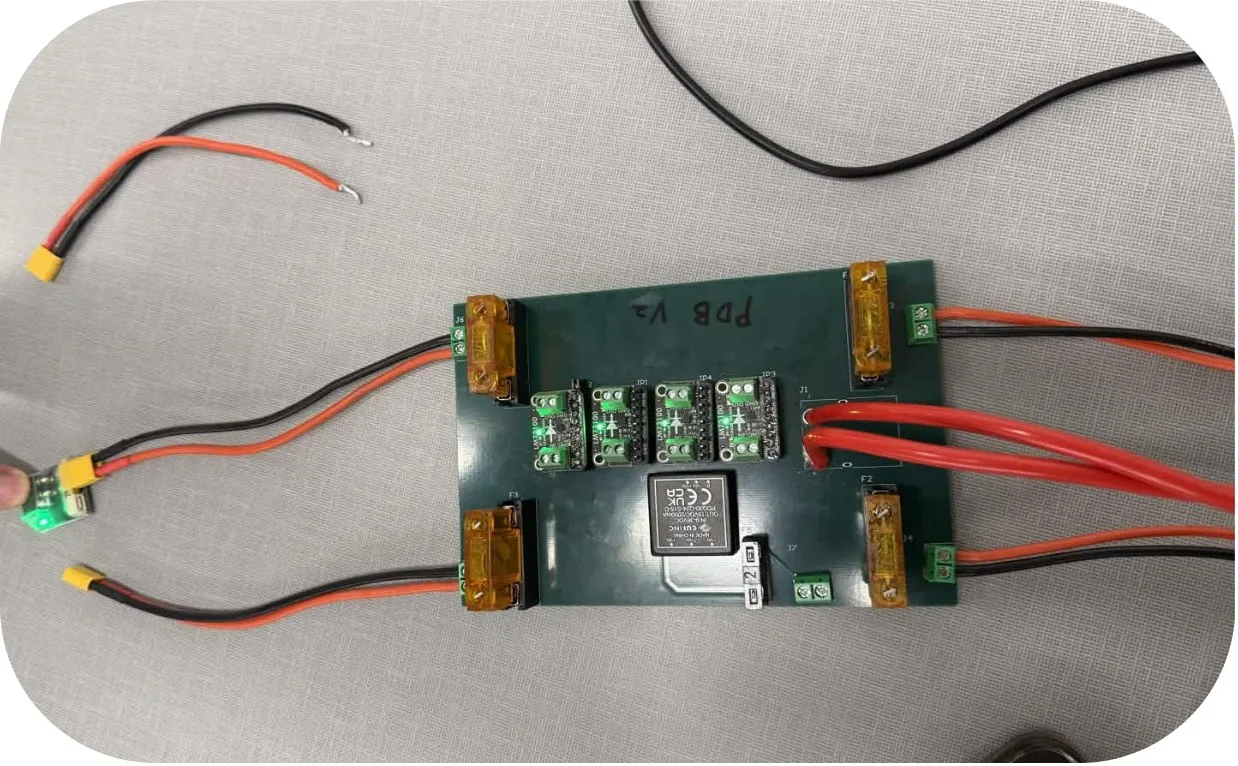
CCBR custom power distribution circuit board with wiring
A custom power distribution board
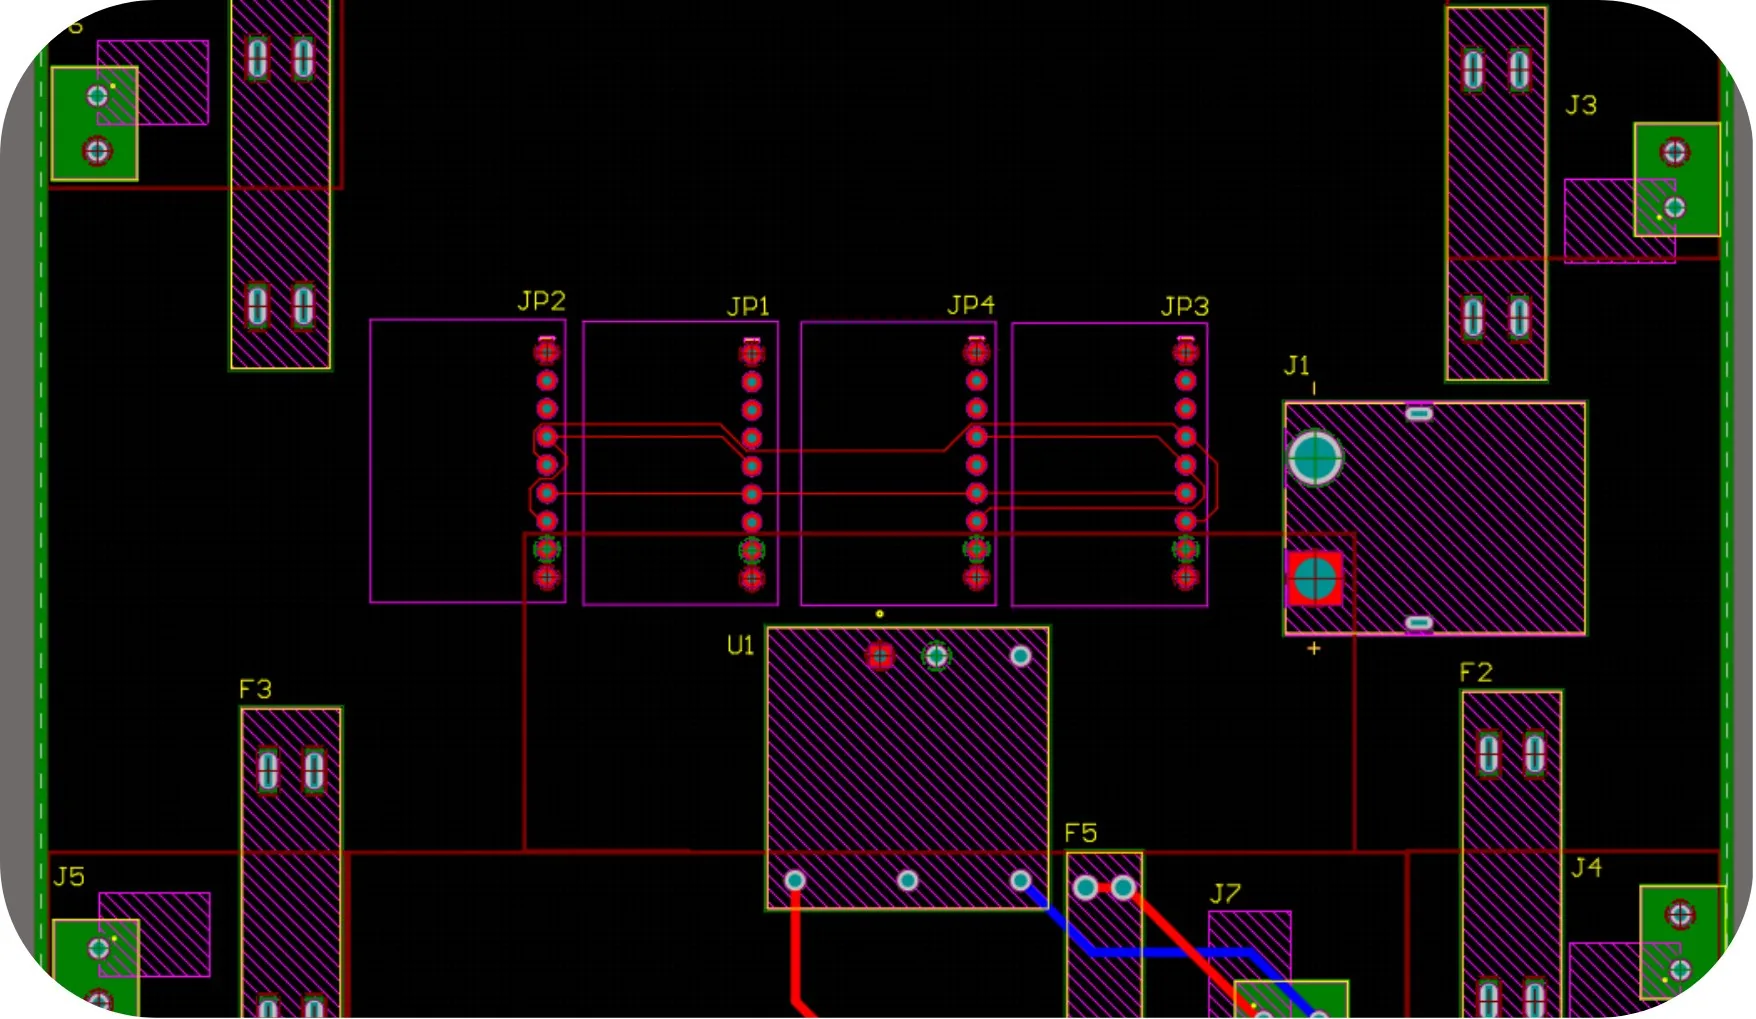
PCB layout for CCBR robot control electronics
The board layout before fabrication

Join the team to build alongside students at partner universities and help shape the next stage of the platform. Thank you for reading until the end. ^^